What it is
Terrestrial Interface for Dhairya's Intelligence. It's an old RC car I'm reviving with an Arduino R4. It will be GOFI's interface into the physical world.
Why
JARVIS wouldn't have been as cool as it was if it were just a computer program. What GOFI needs is a physical body it can control.
How it works
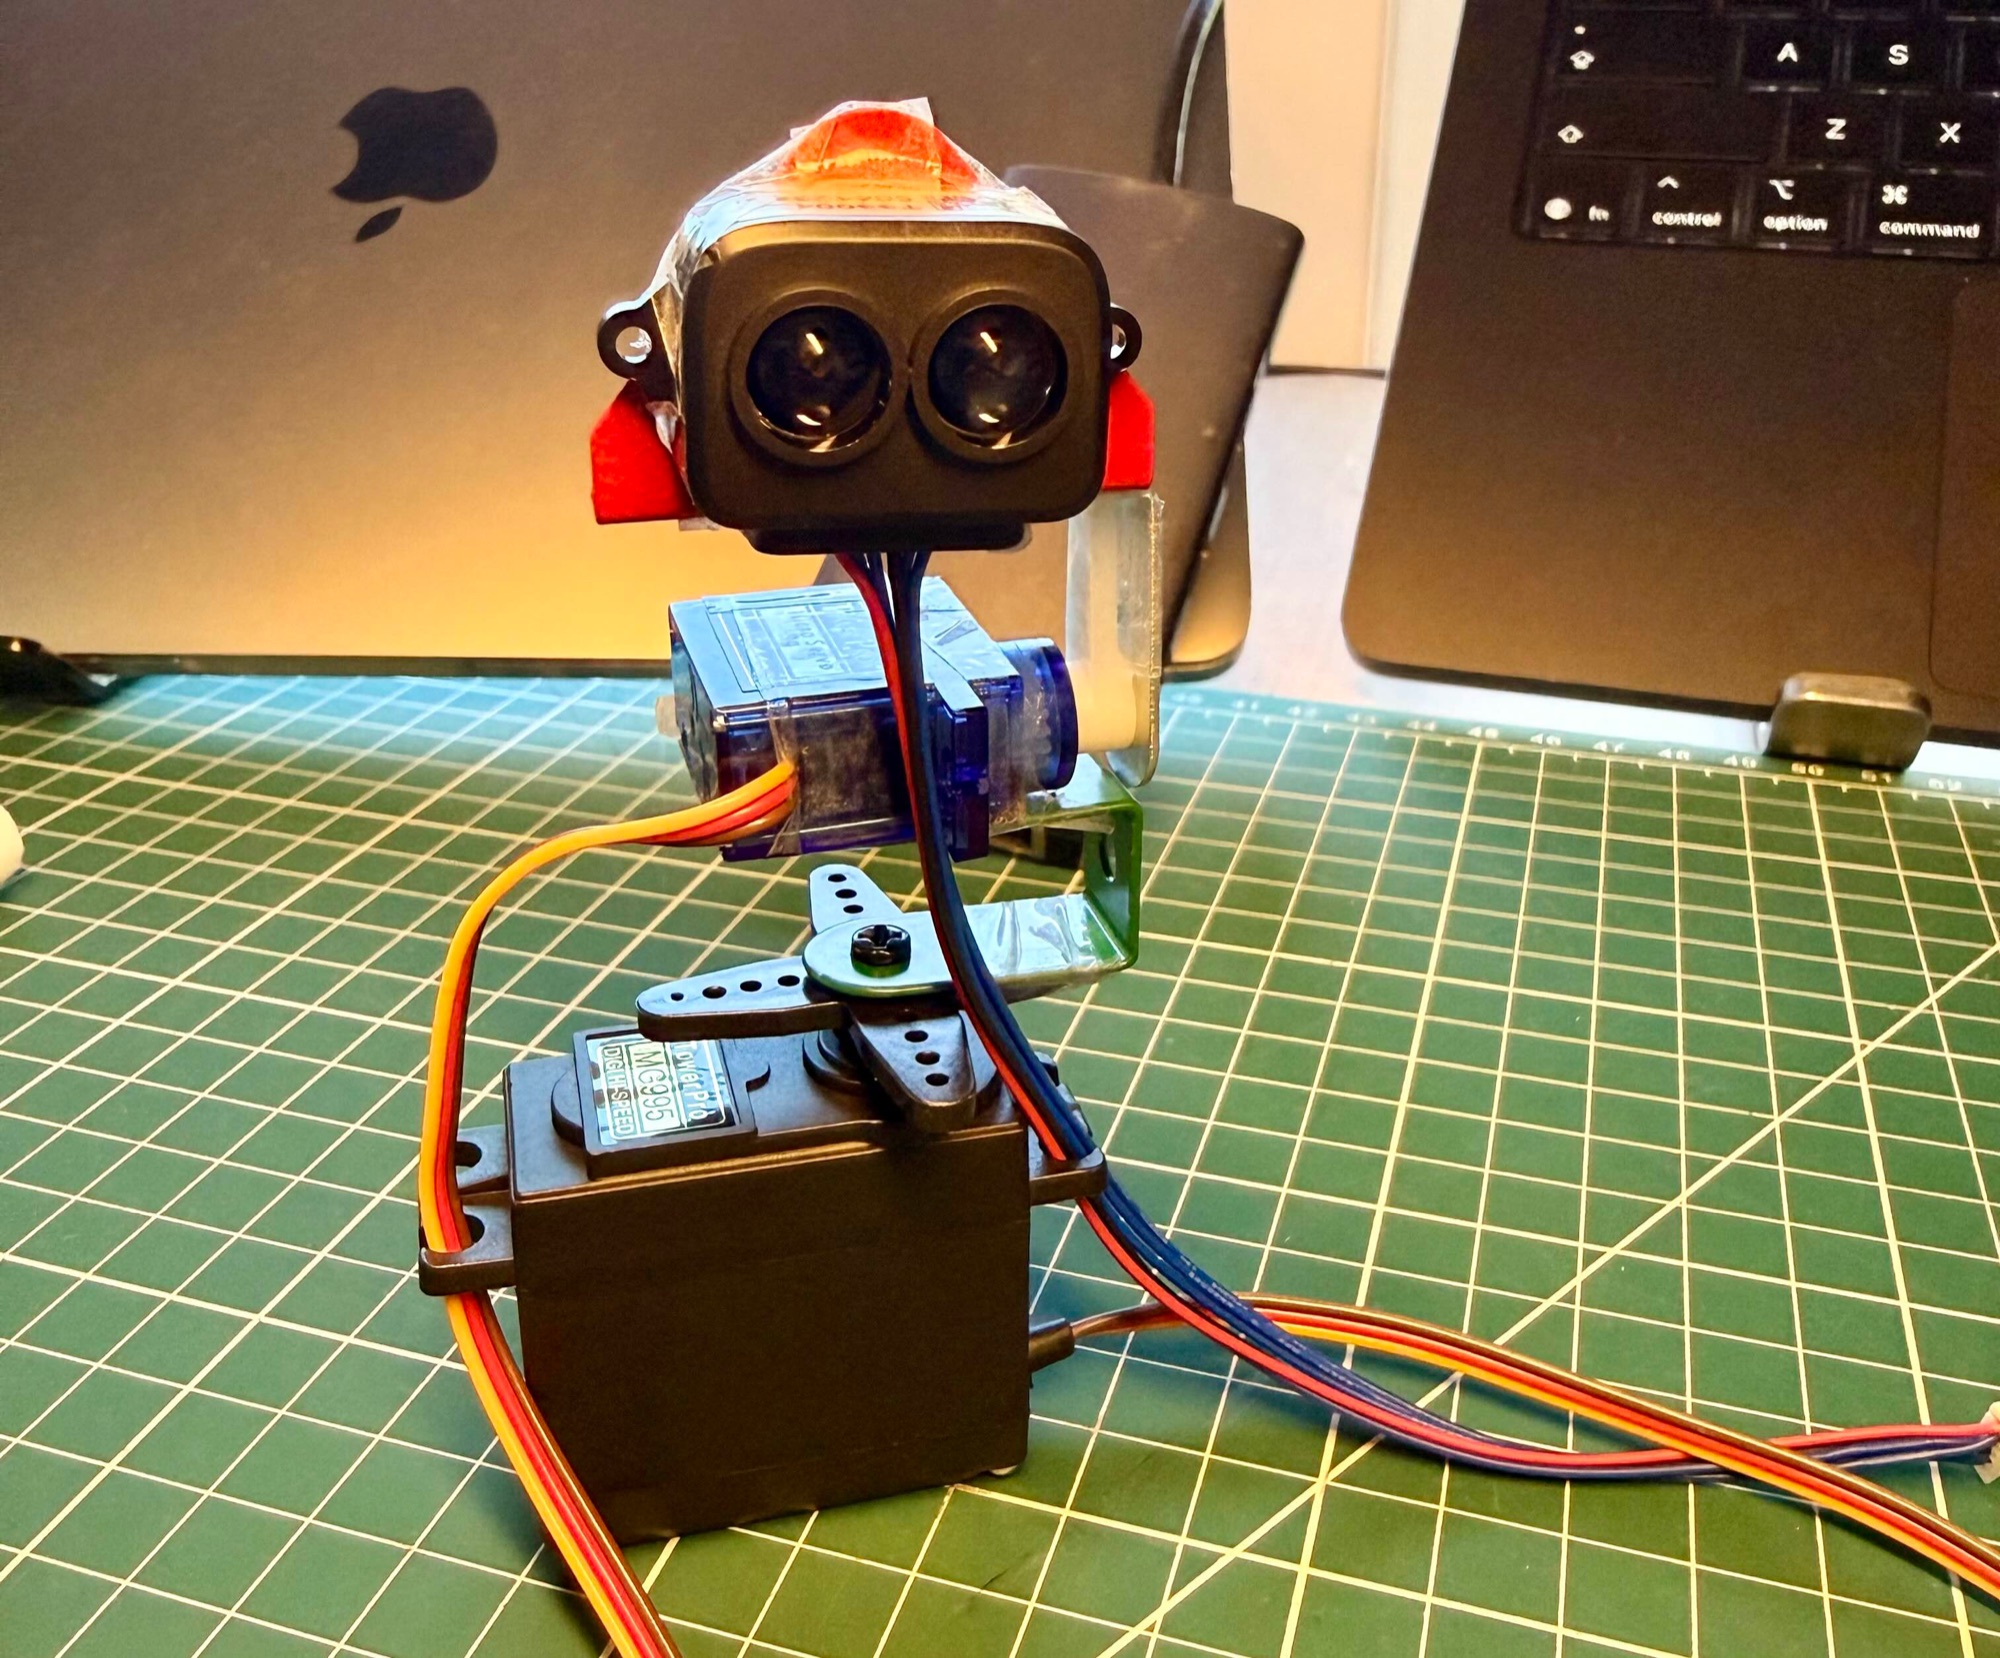
A TF-Luna LiDAR sits on a tilt servo, and that sits on a continuous-rotation servo that turns it in azimuth. An Arduino R4 Minima sweeps both and streams the distances over serial, and a Python script on the laptop turns the stream into a point cloud.
The drive side is planned but not built. An ESP32-CAM will handle WiFi and video for GOFI and pass drive commands to the Arduino over I2C. A Cytron MDD3A will drive the 9 V motors from a 3S LiPo, with the PWM capped to hold them at about 7 V.
Where it's at
The LiDAR head is physically built but I'm waiting on a 3S battery pack to arrive so I can properly power it for a scan. I've checked and the motors in the chasis work. Once the battry and other components arrive, I'll get it working first with Arduino only. ESP32 + CAM will come later.
Links
I'll make the github public soon.